Skip to content

Automation

A gripper tool for OLA & Jubilee - Part 3

This is a follow-up post to A gripper tool for OLA & Jubilee - Part 2.

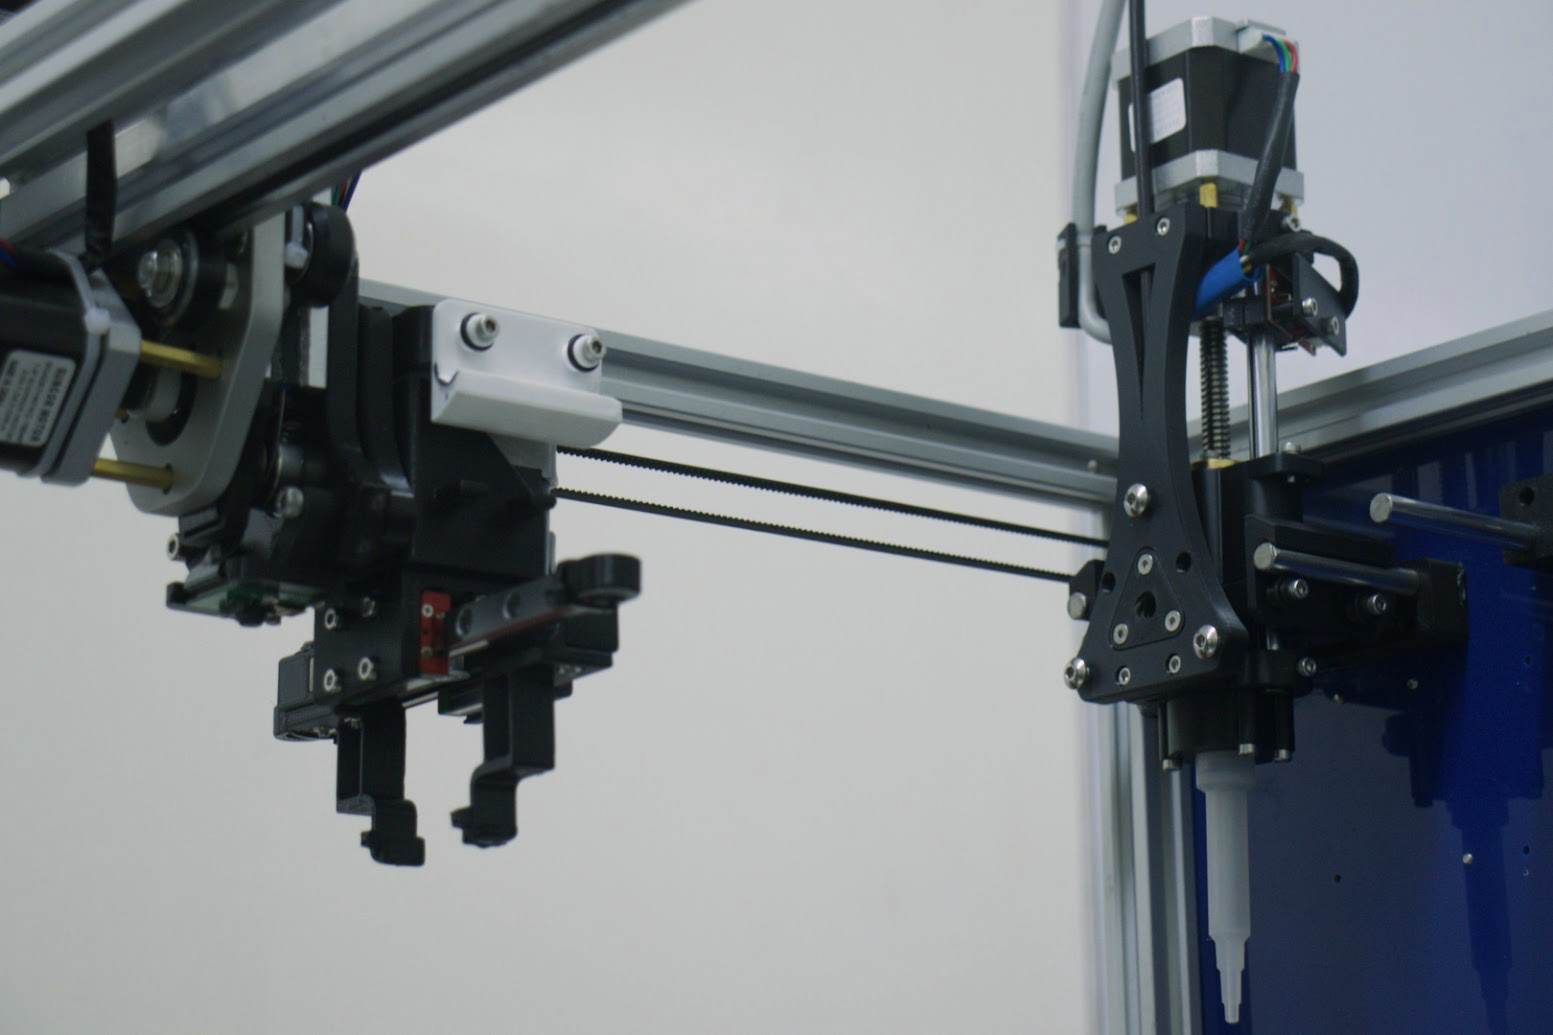
Anxious readers can see the current version in the image below. For the rest, a few words will follow.
alt text

Just the grippy part please

Previously on this gripper saga, I hacked together a tool for grabbing and spinning things. It worked as a proof of concept, but was far from reliable, borderline dangerous.

A recent job required just the grabbing part, not the spinny part. A perfectly boring opportunity to work on the basic mechanism. So, I made a thing.

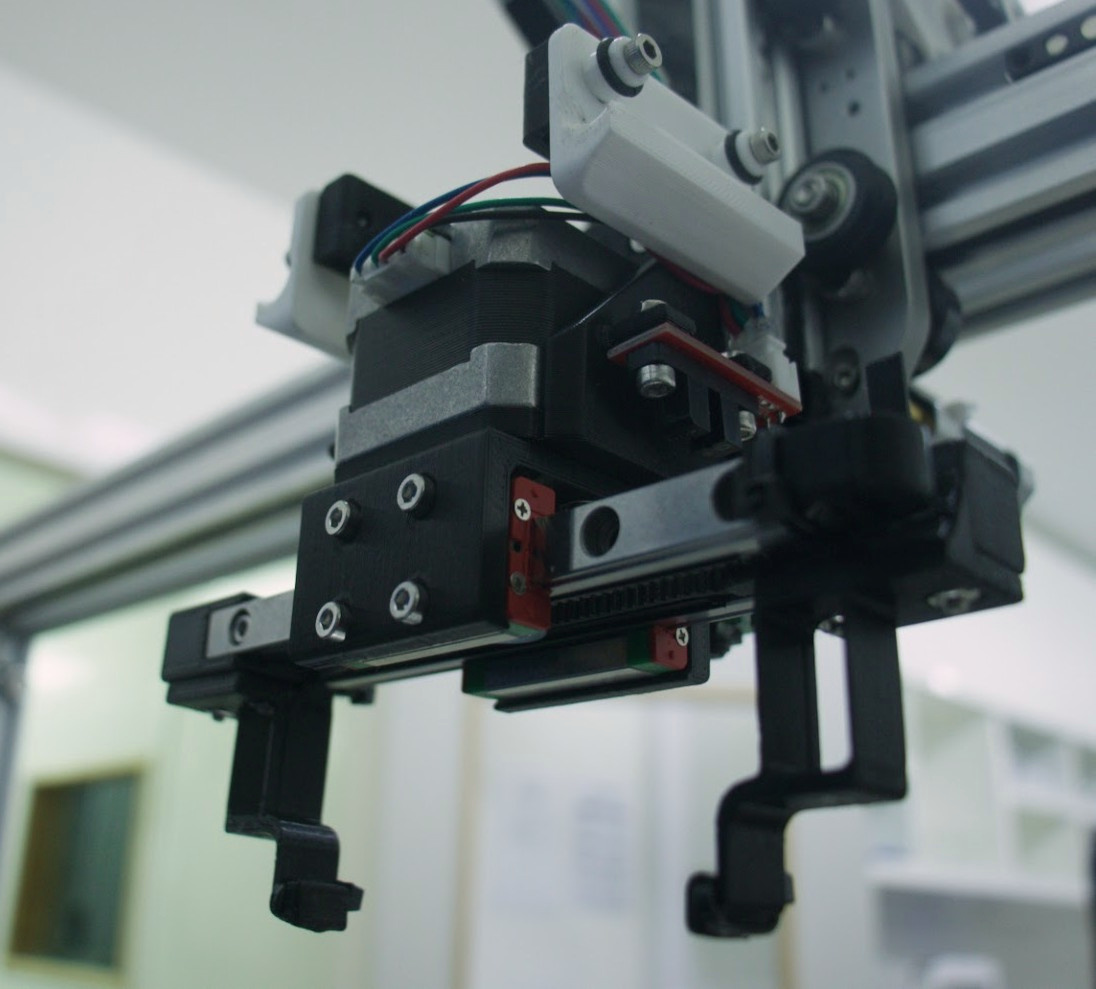
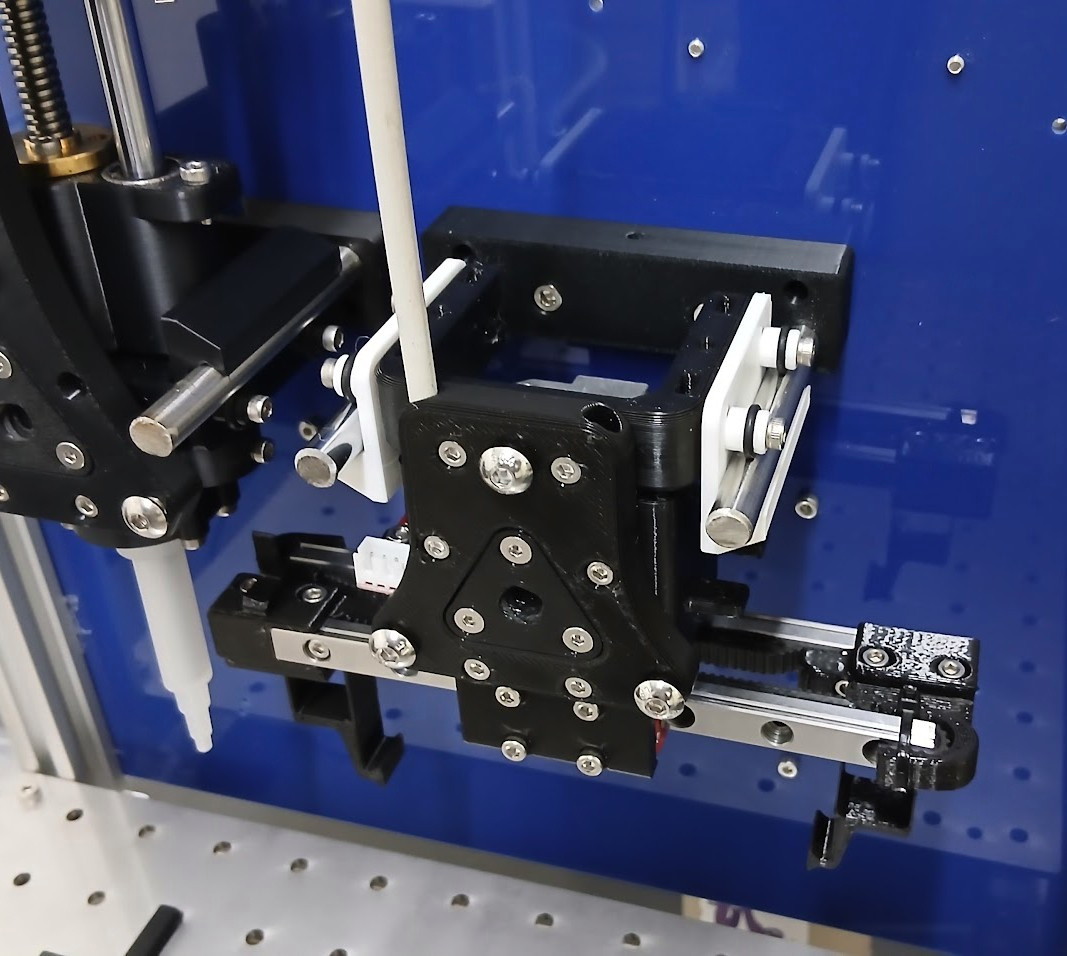
The cleverest part was to use timing belts as a gear rack (instead of 3D printing it, as I did last time), and I and am very happy with how simple the build came out.
alt text alt text

Here is a prosaic parts list:

  • Standard NEMA17 and GT2 pulley.
  • Two strips of timing belt.
  • The cheapest MGN9 linar rails I could get my hands on.
  • Optical endstop.
  • Fasteners and 3D prints.

There's some room for improvement, but the most interesting bit of follow up could be: (1) adding a magnetic encoder to the back of the stepper, (2) use FOC to maximize torque, (3) couple it with current sensing, letting us affect how tight the thing should grip.

Grippers are awesome, and have tons of applications, and synergizes extremely well with the micropipette tool we already designed.

Stay tuned for more!

A gripper tool for OLA & Jubilee - Part 2

This is a follow-up post to A gripper tool for OLA & Jubilee - Part 1.

Background and requirements are listed there.

homing

Tracker: https://gitlab.com/groups/open-la/-/epics/20

Homing Implementation

The wripper sits on a freely-rotating wrist, which makes wiring sensors on the tool-side complicated.

To get around this, the homing sequence proceeds in two ordered steps:

  1. Home the wrist axis.
  2. Align the gripping axis to the second endstop.
  3. Home the gripper.

gripper-cad.png

The most reasonable endstop options, given what i had around, were either optical or magnetic. I went with magnets because they are far more forgiving than opto-endstops in terms of alignment.

I used electromechanical Reed switches, soldered to Makerbot-style endstop boards, each one fixed to the "stator" part of the gripper.

Control

This time I just stuck the control board onto the tool, and routed only 24V and USB to it.

I really didn't want to do any more cable management. Reducing the cable count to just 3 is a real achievement.

Behind this is a firmware capable of syncronizing motion between multiple control boards. At the time of writing, I used my klipper for CNC fork.

With it I get all of the klipper goodies, and two important bits:

  • Kinematics for an additional axis set; A for gripping and B for turning in this case.
  • Homing through generalized probing (i.e. G38 commands) and basic macros.

Klipper is slowly working towards its own multi-axis features, so hopefully I won't have to maintain the fork for too long.

If you know about other firmware projects that might replace Klipper, please let me know. There is now Prunt, but it's not what I am looking for.

Proof of concept

Here is a video of it homing clumsily on a pair of stepper motors: https://www.youtube.com/watch?v=3veRTsW12Zw

Up next

Get involved. Introduce yourself and browse to the OLA tools forum.

Get in touch, join the chat! https://discord.gg/GmCeXTHpM4

A roadmap:

  • Replacing the servos with NEMA8 motors.
  • Print a Jubilee-style tool mount.
  • Add endstops, probably optical, probably coupled to each other (or with just one).
  • Review or redesign the mechanics to fox the jankiness in the motion.
  • Figure out kinematics for rotation & gripping.
  • Have a little fin with it.
  • Integrate to the OLA lab automation stack as a new tool: https://gitlab.com/open-la

There will be a "Part 3", no ETAs though. :)

A gripper tool for OLA & Jubilee - Part 1

After a couple years, this project has finally received my attention.

alt text

Tracker: https://gitlab.com/groups/open-la/-/epics/20

Background

I want a gripper tool for this lab robot: https://docs.openlabautomata.xyz/

Notable previous works include:

Some requirements

  1. Gripping action: for tiny (e.g. seeds) and medium-sized stuff (well-plates and petri dishes). Nothing too heavy.
  2. Wrist action: with unbound spinning angle.
  3. Affordable, ubiquitous components.
  4. Mostly 3D-printed parts.
  5. Upgradable.
  6. Open-source hardware.
  7. Synchronizable motion.

Nice to haves:

  • Eccentric grip.

Implementation

  • Hollow-shaft concept: a pair of concentric shafts transmit force to different parts of the actuator.
    • The broader shaft (8 mm) rotates the wrist.
    • The narrow shaft (5 mm) passes through it, and actuates the gripper claws.
    • Because of this arrangement, the wrist is coupled to the grip action. Both motors will need to turn in sync for the claws to rotate and hold a certain grip.

alt text alt text alt text alt text

Proof of concept

Here is a video of it running clumsily on a pair of servos: https://www.youtube.com/watch?v=_W5kAROLW5M

Up next

Get involved. Introduce yourself and browse to the OLA tools forum.

Get in touch, join the chat! https://discord.gg/GmCeXTHpM4

A roadmap:

  • Replacing the servos with NEMA8 motors.
  • Print a Jubilee-style tool mount.
  • Add endstops, probably optical, probably coupled to each other (or with just one).
  • Figure out kinematics for rotation & gripping.
  • Have a little fin with it.
  • Integrate to the OLA lab automation stack as a new tool: https://gitlab.com/open-la

Check out "Part 2" of this project.